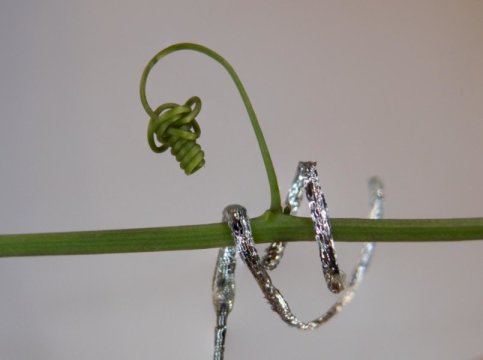
Researchers took inspiration from plants and their movement. Indeed, being unable to escape (unlike animals), plants have associated their movement to growth, and in doing so they continuously adapt their morphology to the external environment. Even the plants organs exposed to the air are able to perform complex movements such as, for example, the closure of the leaves in carnivorous plants or the growth of tendrils in climbing plants, which are able to coil around external supports (and uncoil, if the supports are not adequate) to favor the growth of the plant itself.
The researchers studied the natural mechanisms by which plants exploit water transport inside their cells, tissues and organs to move, and then they replicated it in an artificial tendril. The hydraulic principle is called "osmosis" and is based on the presence of small particles in the cytosol, the intracellular plant fluid.
Starting from a simple mathematical model, researchers first understood how large a soft robot driven by the aforementioned hydraulic principle should be, in order to avoid too slow movements. Then, giving the robot the shape of a small tendril, they achieved the capability of performing reversible movements, like the real plants do.
The soft robot is made of a flexible PET tube, containing a liquid with electrically charged particles (ions). By using a 1.3 Volt battery these particles are attracted and immobilized on the surface of flexible electrodes at the bottom of the tendril; their movement causes the movement of the liquid, whence that one of the robot. To go back, it is enough to disconnect the electric wires from the battery and join them.
The possibility of exploiting osmosis to activate reversible movements has been demonstrated for the first time. The fact of having succeeded by using a common battery and flexible fabrics, moreover, suggests the possibility of creating soft robots easily adaptable to the surrounding environment, thus with potential for enhanced and safe interactions with objects or living beings.
Possible applications will range from wearable technologies to the development of flexible robotic arms for exploration. The challenge of imitating plants' ability to move in changing and unstructured environments has just begun.
In this context, Mazzolai and her research team are involved as coordinator in a new project, named "GrowBot," which is funded by the European Commission under the FET Proactive program, and it envisages the development of a robot that is able to manage its growth and adaptation to the surrounding environment with the capability to recognize the surfaces to which it attaches, or the supports to which it anchors. Just like the real climbing plants do.
A variable-stiffness tendril-like soft robot based on reversible osmotic actuation.
Indrek Must, Edoardo Sinibaldi, Barbara Mazzolai.
Nature Communications, 2019; 10 (1)
DOI: 10.1038/s41467-018-08173-y
Contact information:
Barbara Mazzolai
Director & Coordinator of Center for Micro-BioRobotics in IIT
barbara.mazzolai@iit.it
Tel: 0039 050 883444
URL: https://mbr.iit.it/about/barbara-mazzolai.html
Istituto Italiano di Tecnologia (IIT)
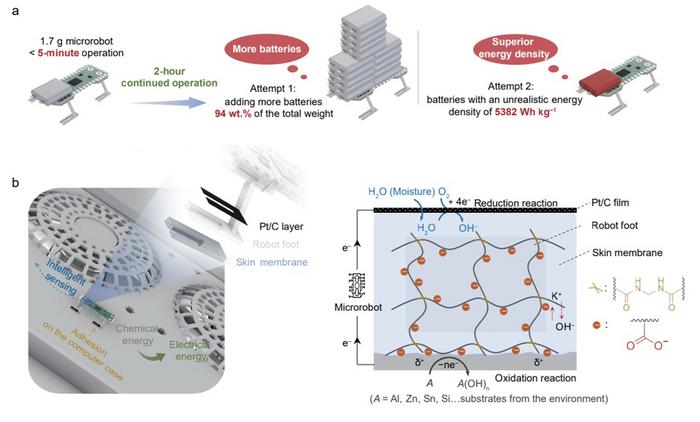
A Fudan University team has built a microrobot skin that generates electricity from the surface it walks on, eliminating onboard batteries. The crosslinked potassium polyacrylate membrane, as thin as 135 micrometres, reacts with aluminum, zinc and other active substrates plus atmospheric moisture and oxygen, reaching 133 mW cm−2 on zinc, roughly ten times typical microbatteries.
In northeastern Brazil, termites have transformed an area about the size of Great Britain by sensing their environment, communicating with each other about it and working together to build vast tunnel systems. Inspired by this and other instances of the small but mighty collective activity in nature, Cornell physics researchers have made robots that for the first time can sense the temperature of their surroundings and react together to change it. “Little things can have a large impact,” said...
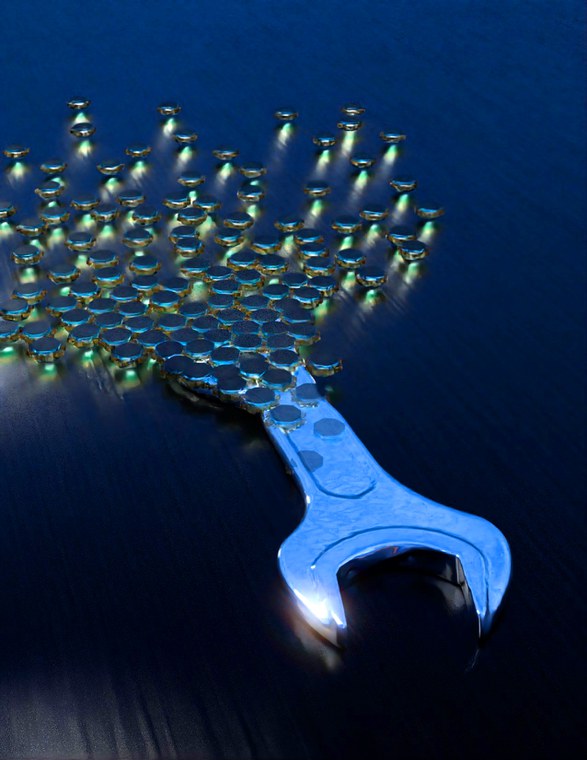
In the world of robots, the equivalent of cell-cell adhesion is achieved with magnets, which are incorporated into the perimeter of the robo
This week in nanotech
$108.5M raised
7 funding rounds · 37 deals tracked
New products
 Nion-compatible In Situ STEM Holders for Electrical BiasingHummingbird Scientific Featured
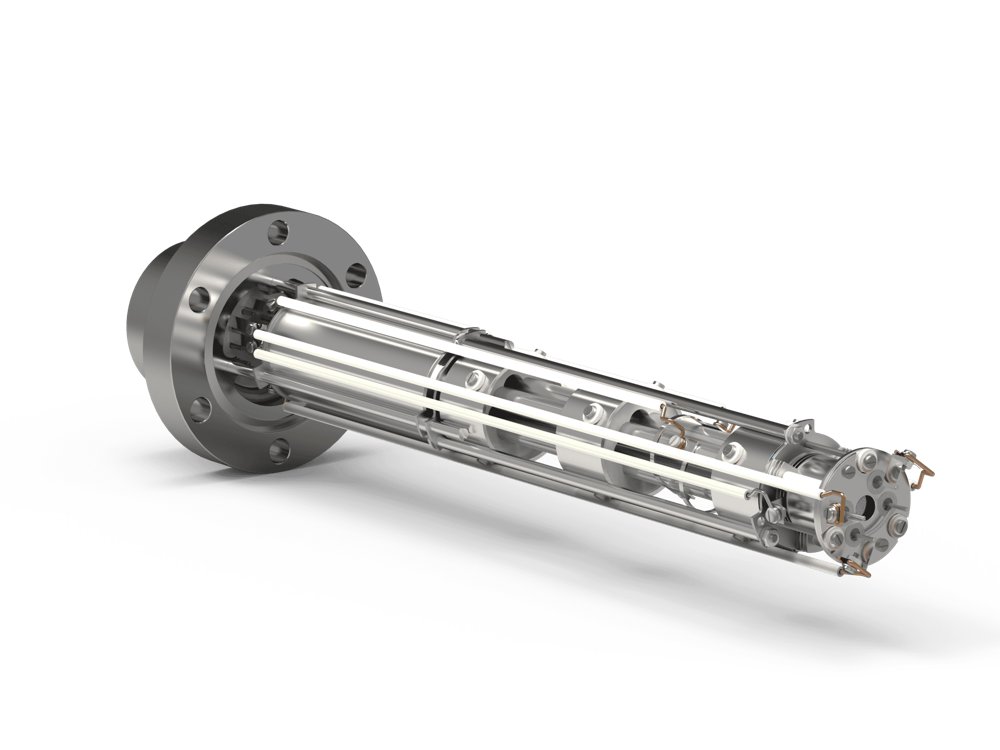 DLS-1 Mass Spectrometer for Fusion Gas AnalysisHiden Analytical Featured
 SunscreenUnchained Labs
Market insights
Last 30 days: Quantum Technologies drew the most money: $3.17B.
Money raised per month